AI & ML
Data-driven control of polynomial systems using implicit methods
arXiv cs.SY0 views
arXiv:2611.24600v1 Announce Type: new Abstract: While conventional behavioral data-driven control represents linear time-invariant (LTI) systems directly from data, extending these data representations to nonlinear systems remains an open challenge. We address this gap for general polynomial systems, characterizing their finite-length trajectories as a real algebraic variety defined by implicit polynomial relations rather than explicit equations. First, we provide conditions on measured data under which these data can be used to represent the system. Building on this representation, we formulate data-driven simulation and predictive control problems that are equivalent to their model-based counterparts, and solve the resulting polynomial systems globally using homotopy continuation. Numerical case studies confirm the effectiveness of this approach by successfully simulating a stiff Van der Pol oscillator in situations where explicit models fail. Furthermore, these data-driven simulation and control methods are illustrated on a Duffing oscillator, demonstrating that our method outperforms Koopman-based approaches in predicting long trajectories.
Source:https://arxiv.org/abs/2611.24600PreviousQuantifying the hosting capacity value of workload flexibility for AI data centers: A two-stage electricity-computation co-optimization frameworkNextData-Driven Factored Abstractions of Stochastic Systems
Related posts
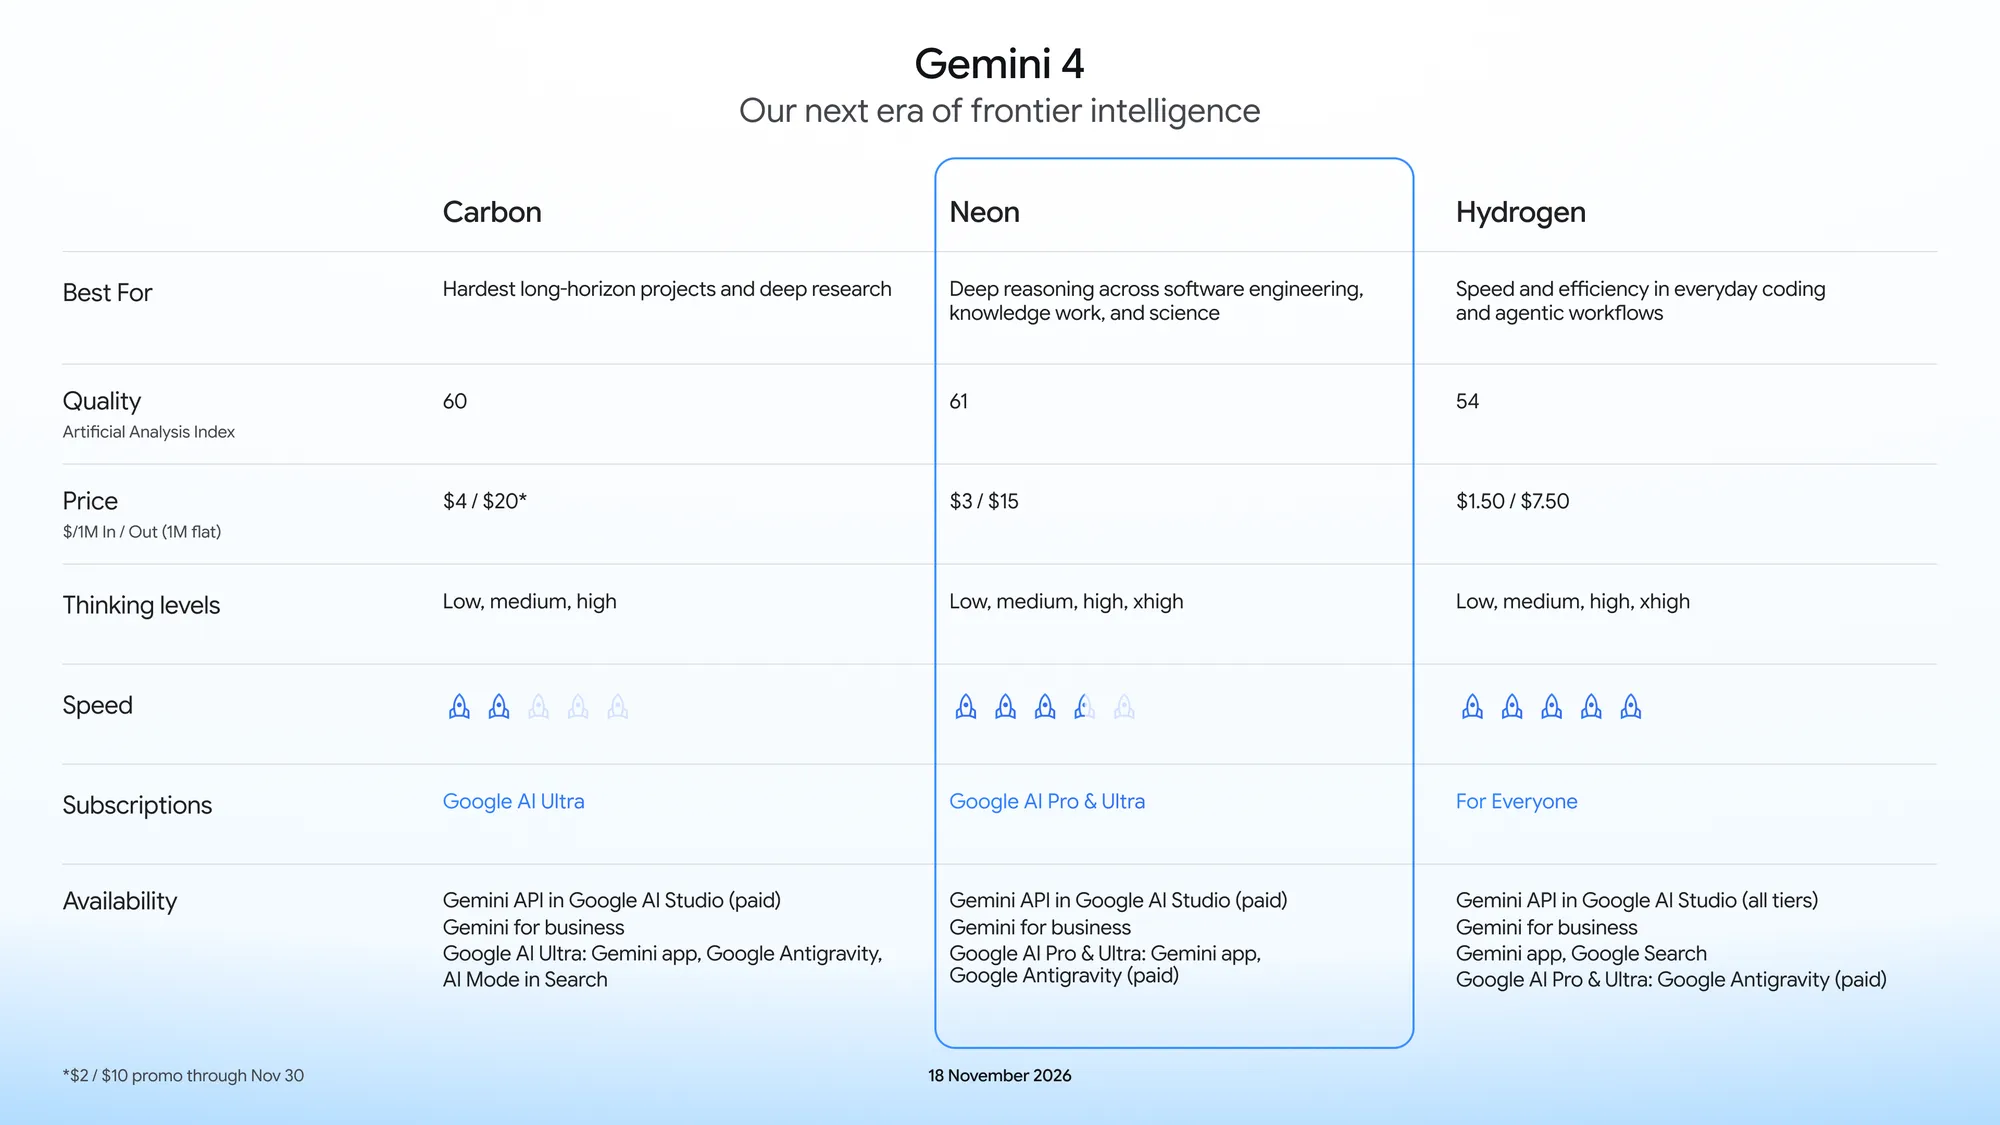
llm-gemini 0.38
0Simon Willison

How to detect user frustration in chatbot conversations
0dev.to

Mình Đã Biến Gemini Thành Trợ Lý Cá Nhân Như Thế Nào (Lịch, Drive, Gmail và Những Lần Suýt Toang)
0dev.to

Im looking fr any free ai models / tools are there?, leaVE UR Lights💡
0dev.to

I checked 10 SEO agency websites for AI-search readiness. The real bugs were the boring ones.
0dev.to

How much GPU memory does an LLM need? The whole sum, worked out on real cards
0dev.to