AI & ML
Featherweight flying robot carries its own sensors and computers
Phys.org Tech0 views
Over the past decade, MIT researchers have developed aerial microrobots with bumblebee-like speed, agility and durability for tasks like precision agriculture or search and rescue. But these featherweight microrobots couldn't carry the electronics needed for navigation, forcing them to remain connected to a motion-capture system in the lab.
Source:https://techxplore.com/news/2026-11-featherweight-flying-robot-sensors.htmlPreviousMicroscopic 'polymer fiber forest' helps keep electronics coolNextThe fastest soft robot ever built doesn't need electronics to function
Related posts

Sam Altman says his life is so weird that he’s unfazed by Andrew Garfield portraying him in upcoming movie
0TechCrunch

Account pools for multi-platform posting #lsdxb
0dev.to
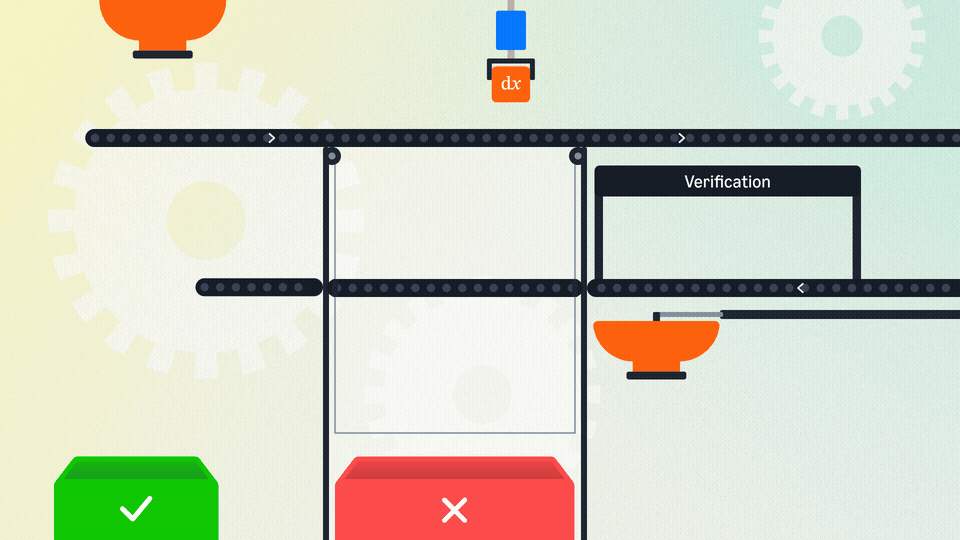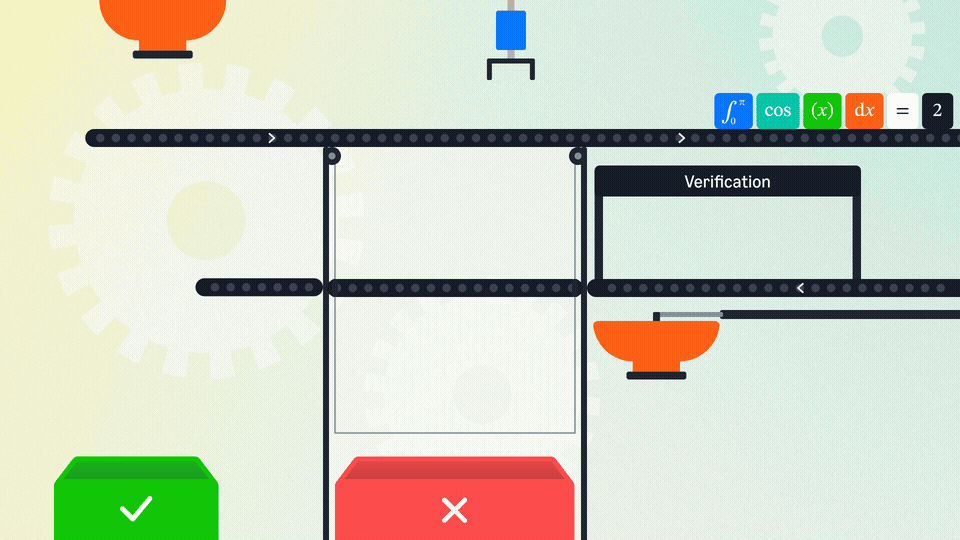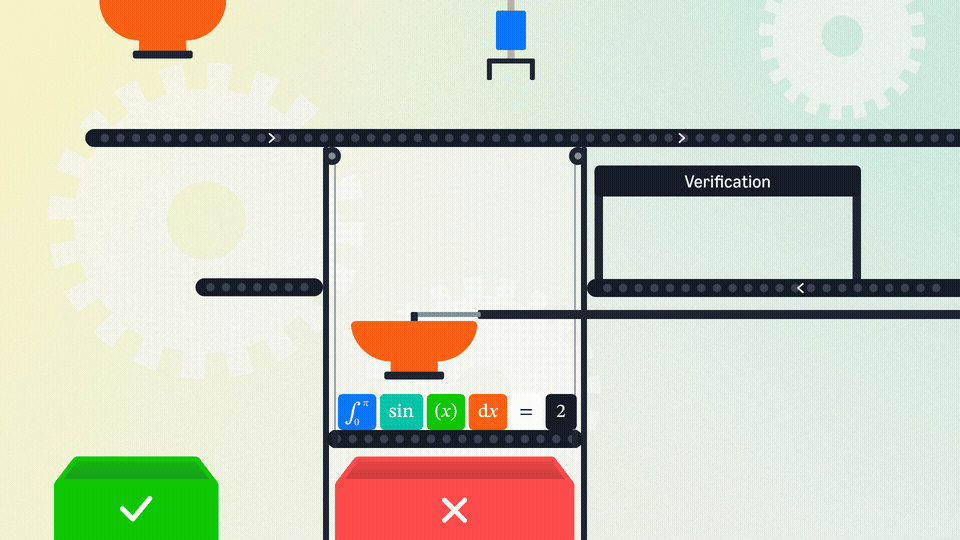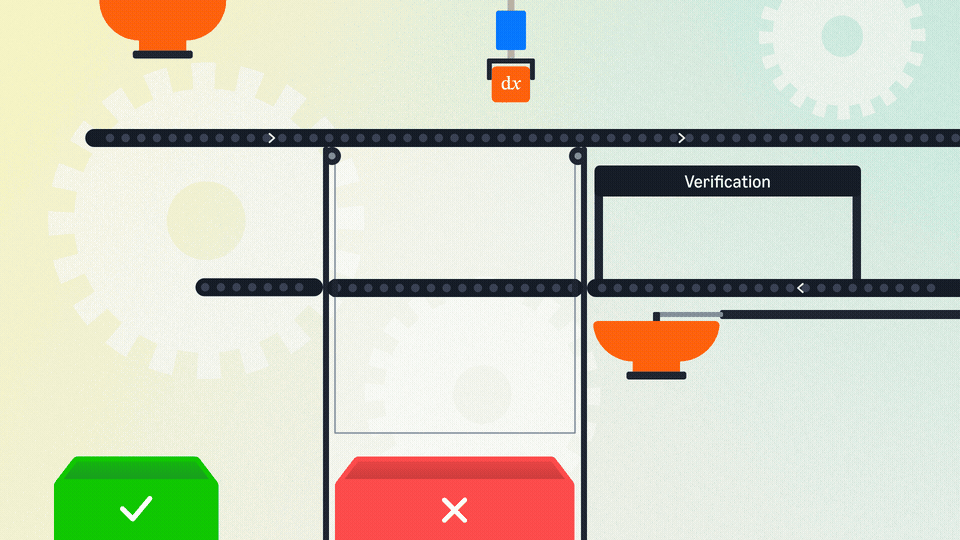
Mathematical proof, powered by AI. And no hallucinations!
0Amazon Science

Qwen4-Max vs. Claude Opus 5.5: The cheaper model costs you somewhere else.
0The New Stack

“The best escape room players that you’ve ever met”: What Red Hat’s AI architect really thinks about agents.
0The New Stack

Microsoft says Bing serves 1B people. Its next search engine isn’t for them.
0The New Stack